Case study · An injection-moulding plant in the United States
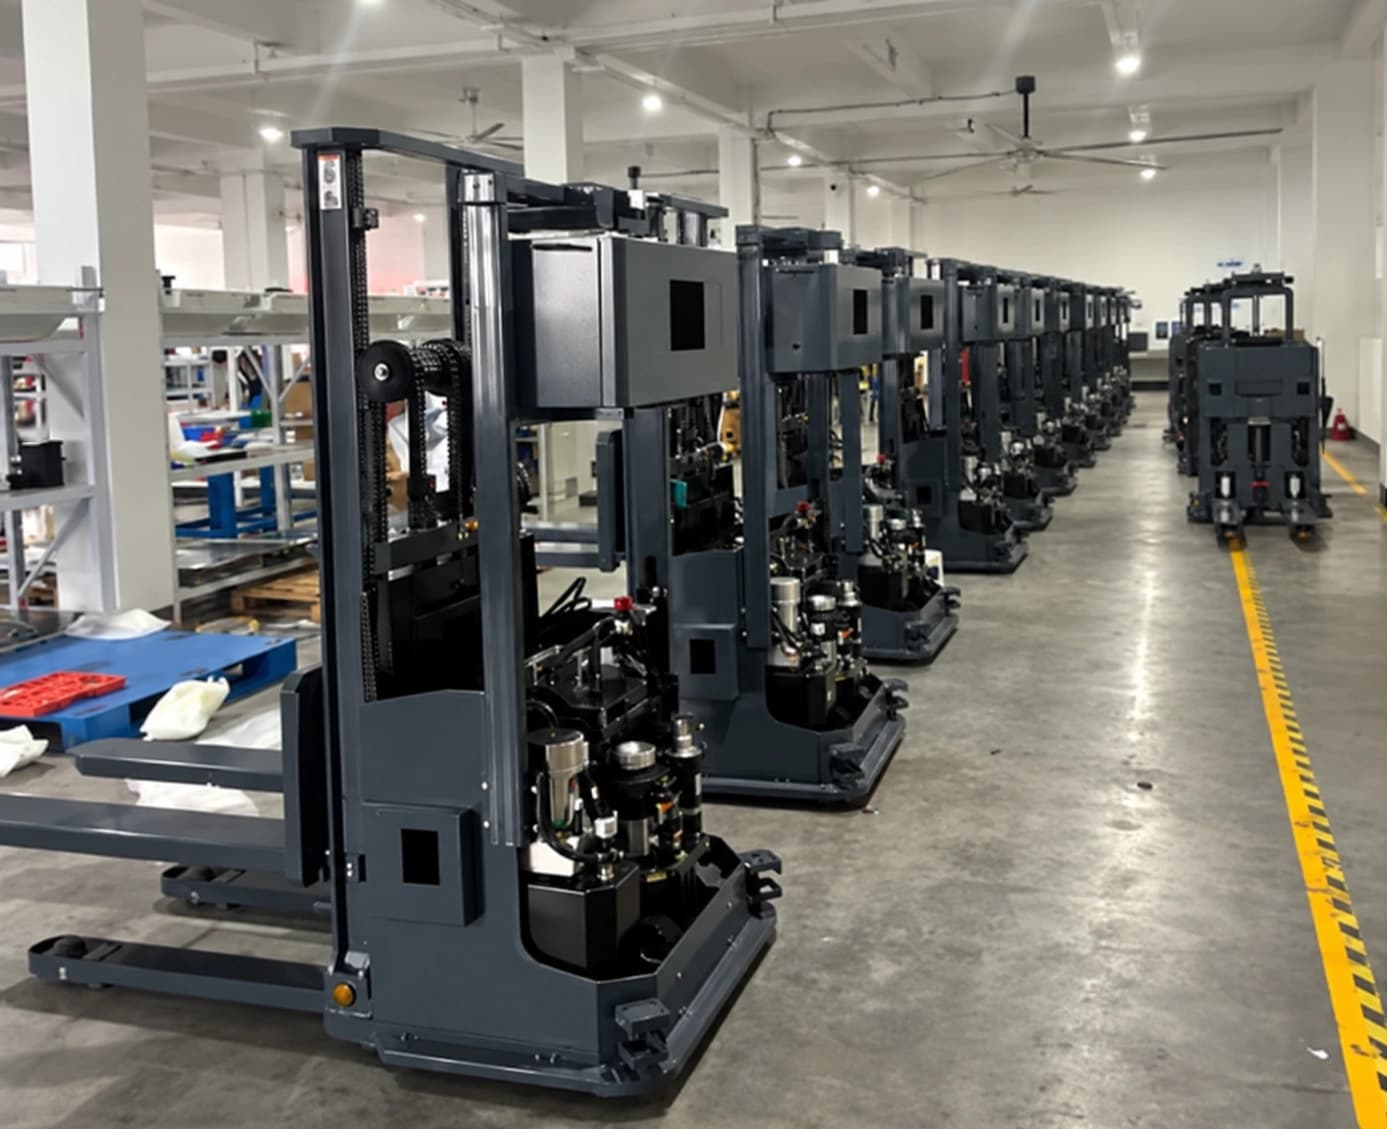
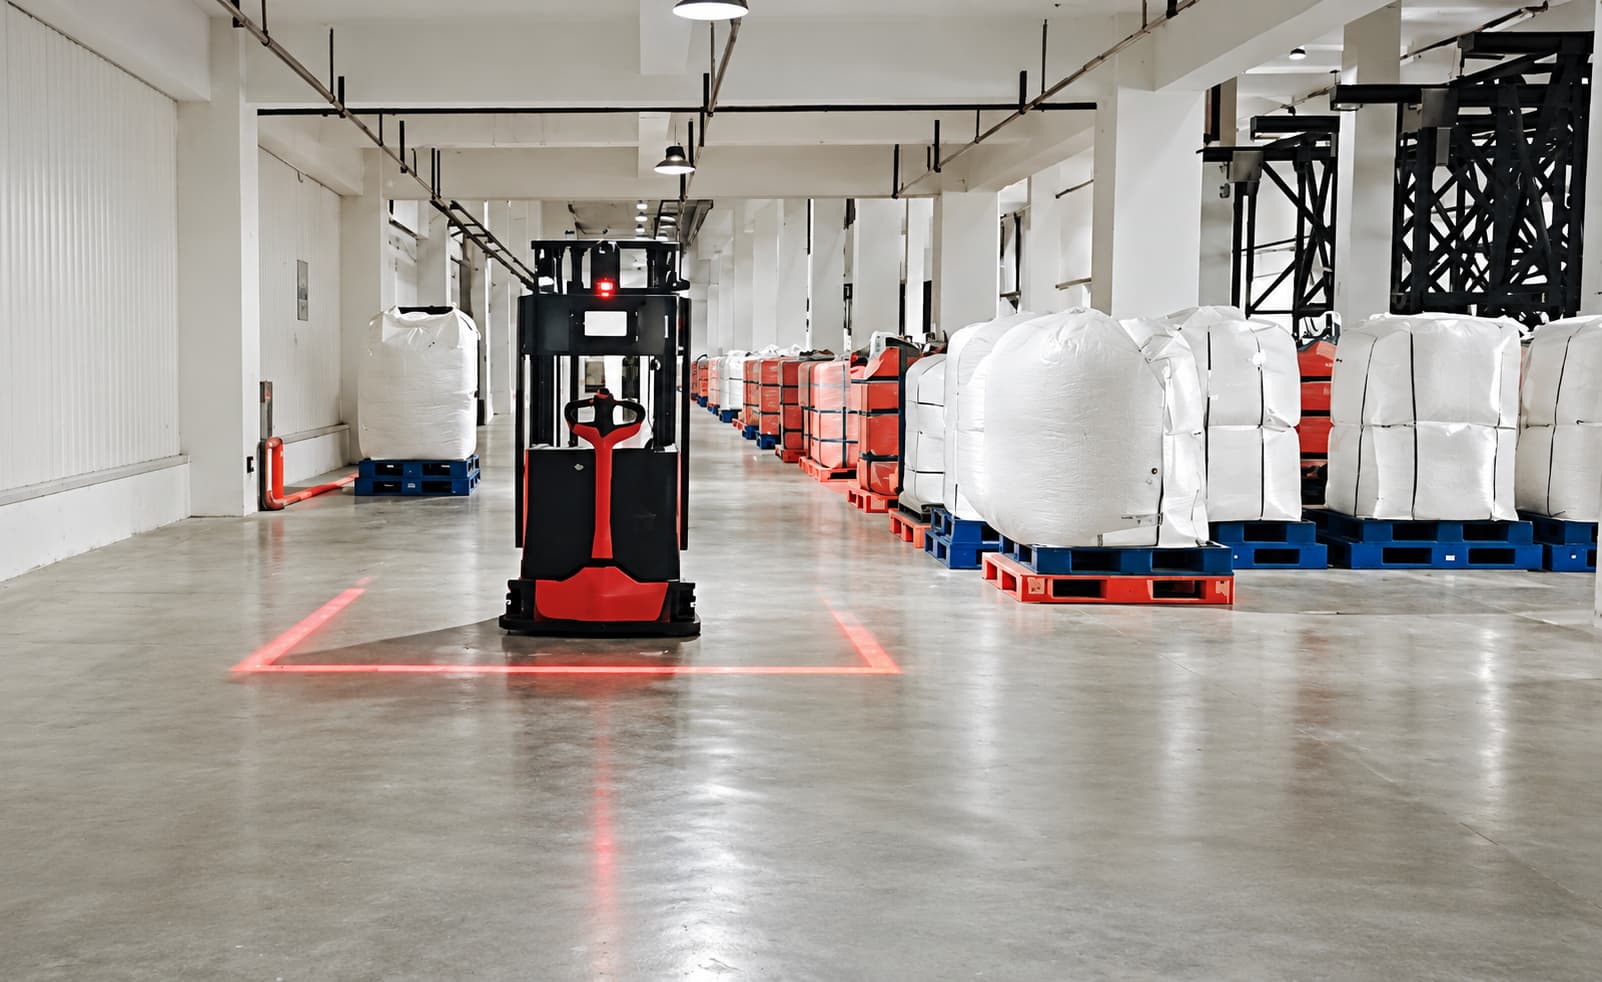
Stacker AGVs taking full pallets off the line at a US injection-moulding plant
Full-pallet offload + empty-pallet return
Custom long forks
WMS / WCS integration
United States
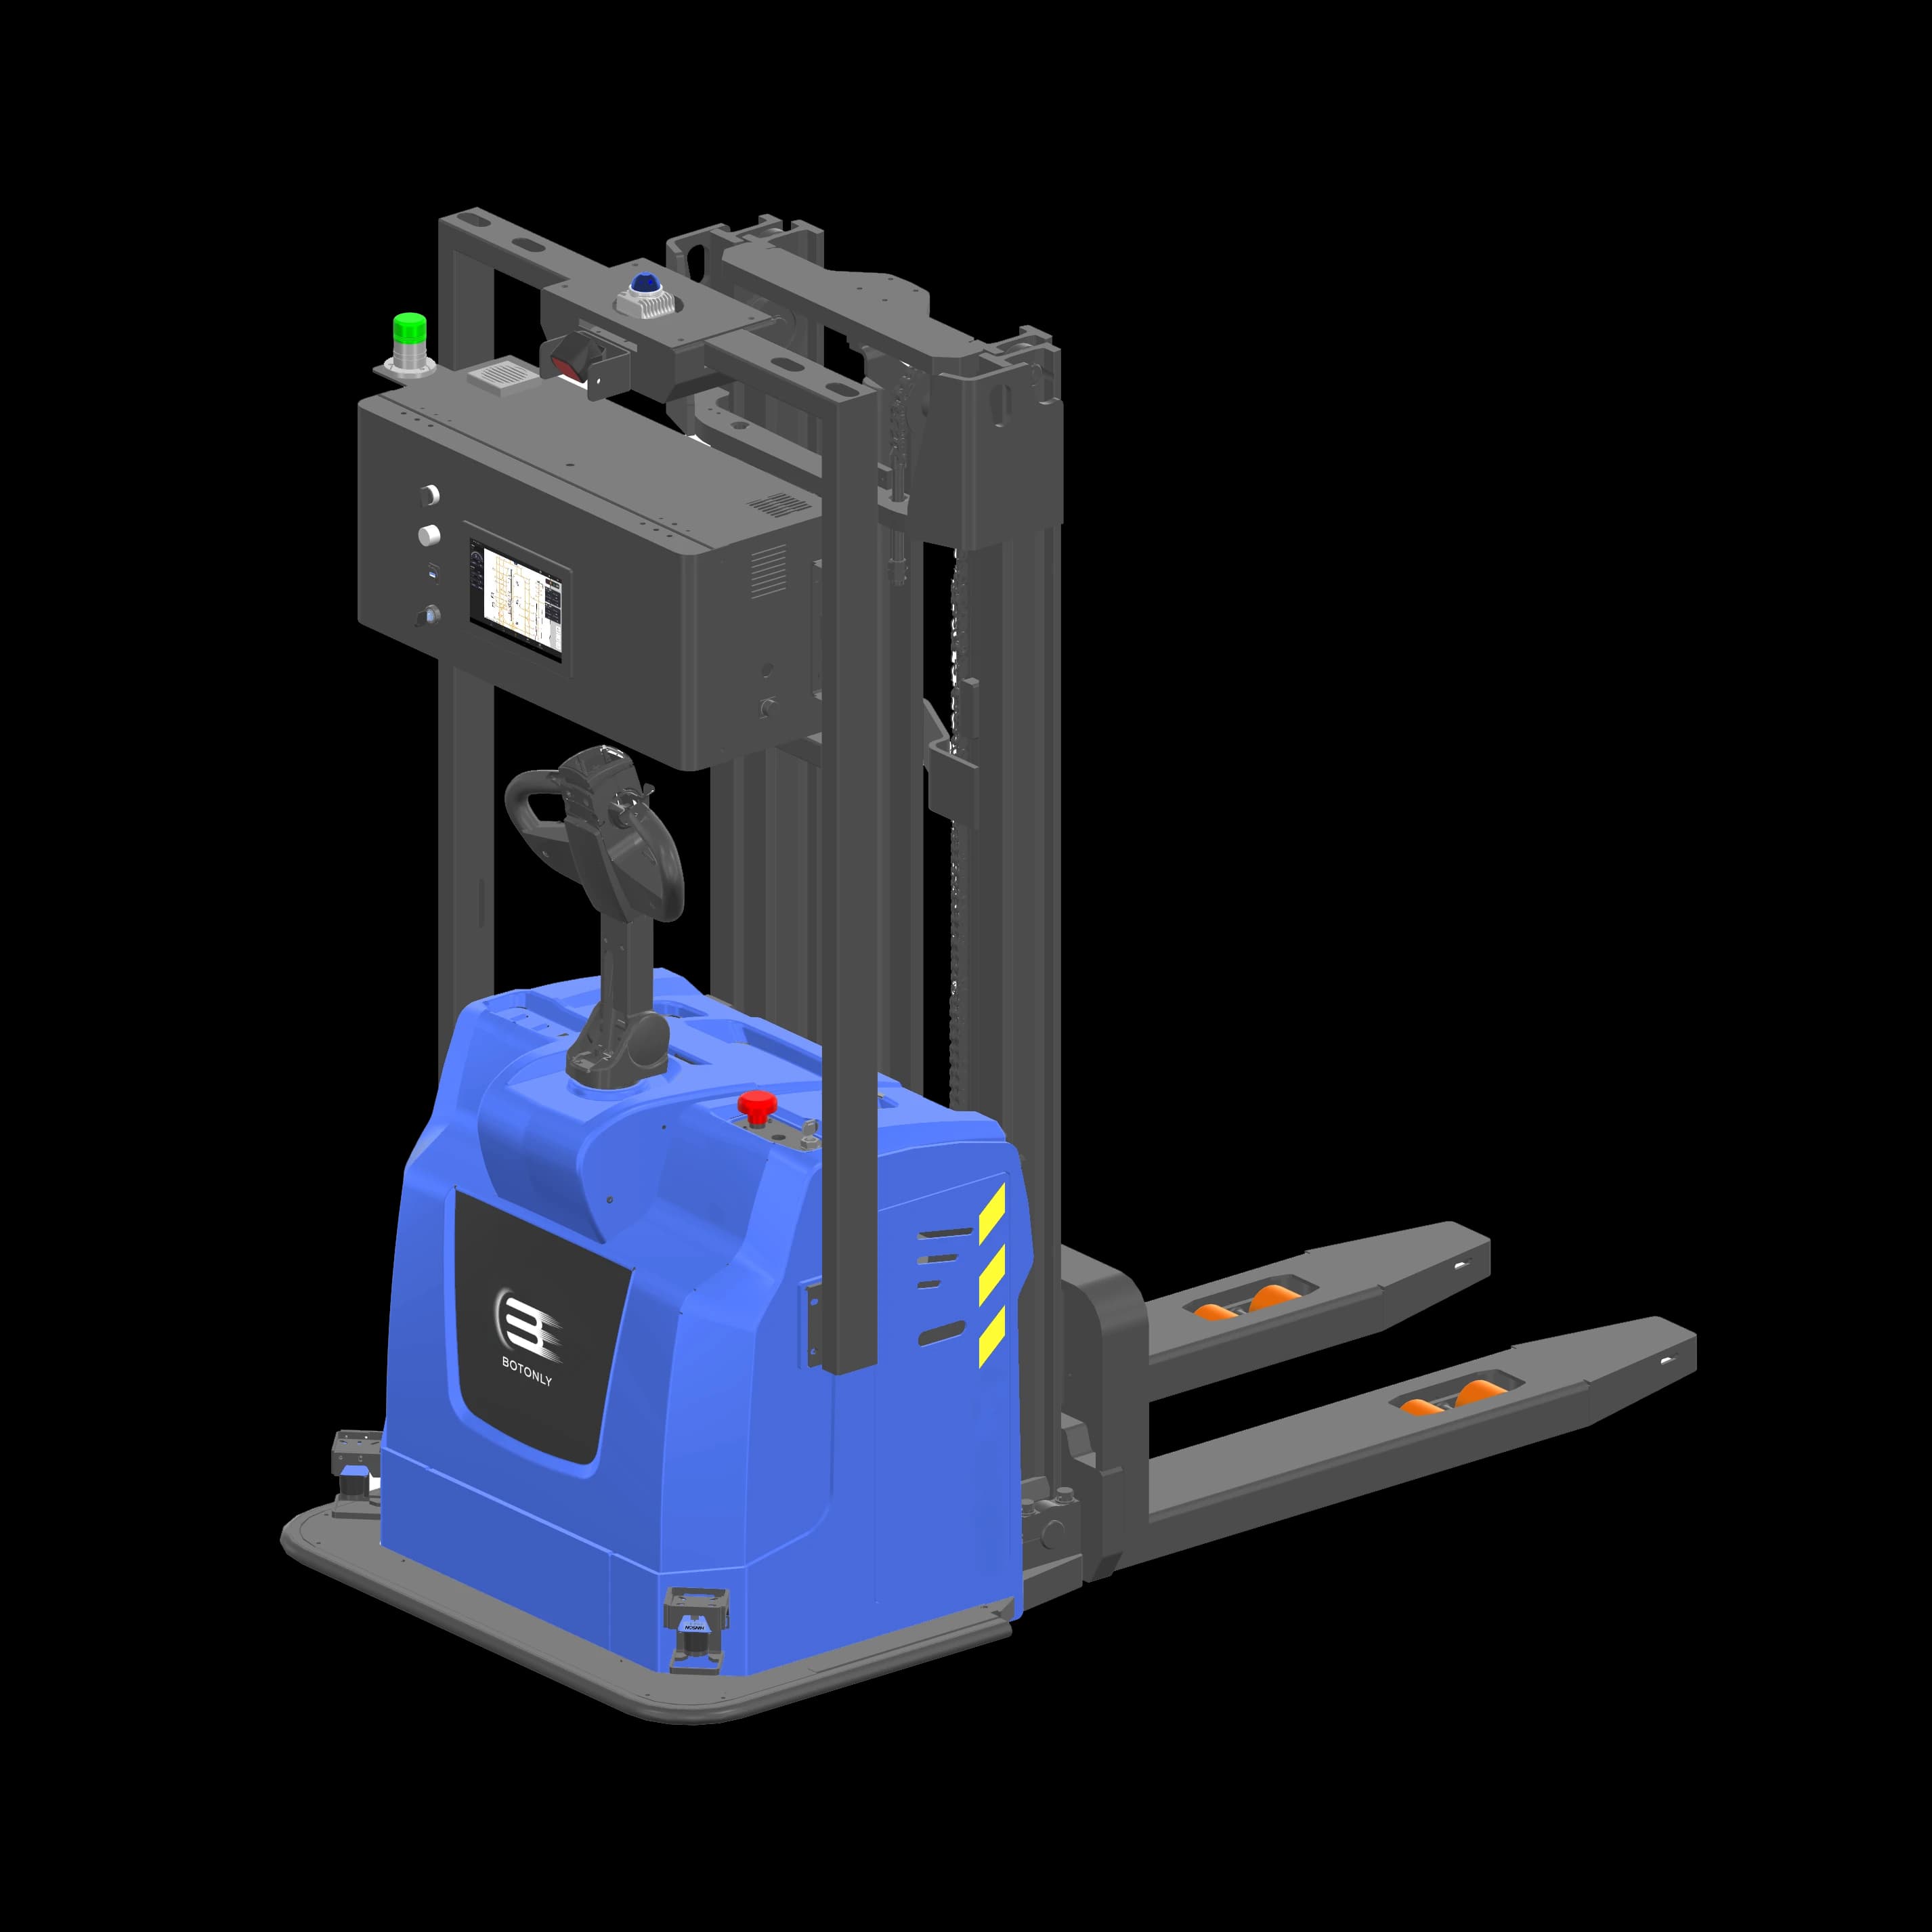
Deployed by the manufacturing partner that builds the BotOnly STC series, at an injection-moulding plant in the United States. The vehicles are the same class as the STC-PS stackers we supply. Product category: Autonomous stackers
At a glance
A large injection-moulding plant needed finished pallets taken off the line and empty pallets returned without forklift drivers, on a floor with non-standard pallet positions. Stacker AGVs with custom long forks now run the full loop, with every move reported to the WMS.
About the plant
A large injection-moulding operation in the United States. Finished goods come off the presses on pallets; empty pallets have to be returned to the line. Labour for in-plant material moves was hard to hire and keep.
The challenge
- Pallet positions at the line were low and not standard, so a stock stacker could not pick reliably.
- The plant wanted inventory updated the moment a pallet moved, not after a scan at the dock.
- Vehicles had to match the plant's visual-management colour scheme and run alongside existing equipment, without a large rebuild.
The solution
Stacker AGVs with extended forks for the plant's pallet geometry, tuned for low pick heights, finished in the customer's colour. Pallet conveyors hand off to the vehicles at the line end. The fleet is integrated with the plant's WMS, WCS and robot management system, so each move updates stock in real time and the vehicles and conveyors trigger each other. Deployed without a major change to the floor layout.
The result
Full-pallet offload and empty-pallet return now run without forklift drivers. The partner reports lower labour cost for in-plant moves and better use of storage positions through real-time WMS updates.
Plan a similar plant flow.
Share the payload, route and docking points. BotOnly will map the work to a short list of systems for the same class of plant job.